Drive Wheel Reduction Ratio Explained: Choosing 32:1 for AGV Applications
Technical Selection Guide · AGV / AMR Drive Systems
Drive Wheel Reduction Ratio Explained: Choosing 32:1 for AGV Applications
A 32:1 reduction ratio means the motor turns 32 times for every single turn of the wheel. On the Plutools PLT-198 horizontal drive wheel, that converts a 48 V, 3000 W motor running at 3000 RPM and 9.55 Nm rated torque into roughly 93.75 RPM and 260 Nm rated output torque at the wheel, with a 576 Nm maximum torque and a 1500 kg maximum load. This guide explains how that conversion actually works, where the losses sit, and how AGV and AMR engineers should decide whether 32:1 is the right operating point for their vehicle.
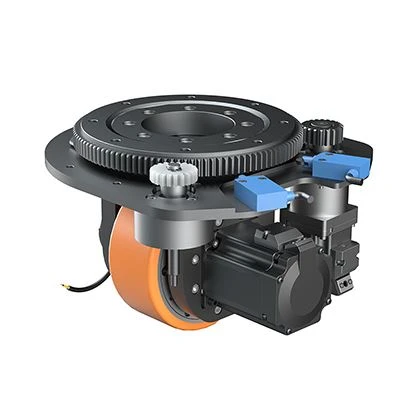
Figure 1 — Plutools PLT-198 planetary horizontal drive wheel with steering: 48 V, 3000 W, 32:1 reduction ratio, 260 Nm rated output torque.
Reduction ratio sits at the centre of every AGV drive wheel specification because it is the one parameter that sets two things at the same time: how fast the wheel turns and how much torque it can deliver. Everything downstream follows from that number — motor current, gearbox life, ramp capability, low-speed positioning quality, and the size of the motor you have to buy.
Plutools (Shanghai Plutools Automation Corporation Co., Ltd.) is a Shanghai-based manufacturer of AGV drive wheels for mobile robots, automated forklifts and material-handling platforms, with a 10,000 m² production facility and a product range covering differential, horizontal, vertical and parallel horizontal drive wheel assemblies. This article uses one of those assemblies, the PLT-198, as a worked example.
Problem Definition: Where 32:1 Decisions Go Wrong
A 32:1 drive wheel is not simply “stronger” than a 21:1 drive wheel. It is a different operating point on the same speed–torque curve, and choosing it decides what your vehicle can and cannot do. Most specification errors at the research and evaluation stage come from three misreadings.
1. Treating motor torque × ratio as available wheel torque
On paper, 9.55 Nm multiplied by 32 gives 305.6 Nm. The published rated output torque of the PLT-198 is 260 Nm. The gap is real transmission loss, and it is the reason a vehicle sized from the ideal figure will underperform in the field. Always size from the published output torque, never from the arithmetic product.
2. Confusing rated torque with maximum torque
The PLT-198 publishes 260 Nm rated output torque and 576 Nm maximum torque — the peak is about 2.2 times the continuous figure. Continuous duty belongs to the rated value; the maximum value covers short-duration demands such as acceleration and braking. Swapping them produces either an oversized, over-costed drive or a thermally stressed gearbox.
3. Treating ratio as a proxy for load capacity
The PLT-198 (32:1, 260 Nm rated, 576 Nm max) is rated for a 1500 kg maximum load. The PLT-210 shares the same 32:1 ratio and the same 260 Nm and 576 Nm torque figures, but is rated for a 1200 kg maximum load. Ratio tells you about torque and speed; load capacity comes from the wheel, bearing set and structural arrangement. They must be specified separately.
Industry Background: Why Ratio Choices Matter More Than They Used To
Drive wheel selection has moved from a mechanical afterthought to a procurement constraint, because the volumes behind it have grown and because more of the load now sits on the drive unit itself.
- The global AGV wheel drives market was valued at approximately USD 1.2 billion in 2024 and is projected to reach USD 3.5 billion by 2034, growing at a CAGR of 11.5% from 2024 to 2034, driven by logistics and warehouse automation (Reports and Data).
- The global AGV market is expected to reach USD 5.9 billion by 2025, with Asia Pacific holding a 37.6% revenue share (Grand View Research).
- The U.S. forklift market reached USD 9.11 billion in 2023, with a visible shift toward electric and automated drive systems (Grand View Research).
- Electric forklifts now command over 70% market share in many regions as a replacement for combustion models (MarketsandMarkets).
- Integrated steering drive modules are replacing discrete components, reducing manufacturer assembly time and maintenance complexity (Brandessence Research).
- Mecanum wheels and omnidirectional drive systems are increasingly used for AMRs in high-density warehouses, while dual differential drive wheels allow a zero-turn radius and are widely used in smaller logistics bots (Interact Analysis; Mobile Robot Guide).
On the compliance side, the reference documents are stable: ISO 3691-4:2023 is the primary international safety standard for driverless industrial trucks and covers steering and braking systems; EN 1175:2020 specifies electrical and electronic safety requirements for industrial trucks; and ANSI/ITSDF B56.5 is the corresponding U.S. standard. A reduction ratio change alters torque at the wheel and therefore braking and steering performance — which is why ratio is a compliance-relevant parameter, not just a performance preference.
Detailed Solution: How 32:1 Behaves on the PLT-198
The PLT-198 is a planetary horizontal drive wheel with steering, built in carbon steel with a PU wheel tread, and specified at 48 V, 3000 W, 68 A rated current, 3000 RPM, 9.55 Nm rated motor torque, 32:1 reduction ratio, 260 Nm rated output torque, 576 Nm maximum torque and 1500 kg maximum load.
The speed chain
Output speed is motor speed divided by the ratio: 3000 RPM ÷ 32 ≈ 93.75 RPM at the wheel. Linear travel speed then depends on wheel diameter, using v = π × D × n ÷ 60, where D is the wheel diameter in metres and n is the output speed in RPM. With a fixed ratio, the only lever left for travel speed is wheel diameter — which is exactly why the ratio must be chosen together with the wheel, not before it.
The torque chain
Torque multiplies by roughly the ratio, minus transmission losses. A 32:1 unit turns a 9.55 Nm motor into a 260 Nm wheel output. At the motor shaft, the 576 Nm maximum torque corresponds to about 18 Nm, so the gearbox is not the only component being loaded at peak — the motor winding and the braking system see that peak too.
The motor efficiency argument
The practical reason to use a high ratio rather than a large motor is that the motor keeps spinning at 3000 RPM and low torque, where a compact 48 V unit can hold rated output, instead of being pushed into a stalled high-torque regime. The cost is current: the PLT-198 draws 68 A at rated output, so battery, cabling and driver sizing must be checked against that figure rather than against the motor’s nominal wattage alone.
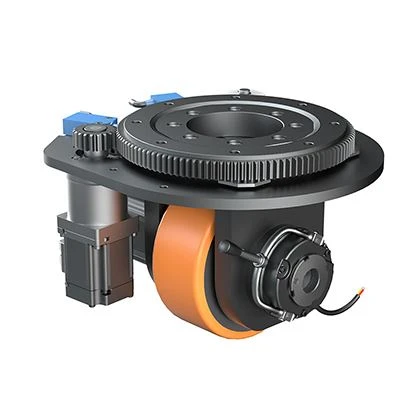
Figure 2 — The PLT-198 integrates motor, planetary gearbox, wheel, encoder and brake into a single steering-capable assembly.
Step-by-Step Breakdown: A Ratio Selection Framework for AGV and AMR Engineers
Step 1 — Calculate wheel-level torque demand
Build the torque requirement from rolling resistance, gradient and acceleration: total tractive force equals (m × g × rolling coefficient) + (m × g × sinθ) + (m × a). Divide by the number of driven wheels, multiply by wheel radius, and add a safety margin. This gives the continuous torque each drive wheel must hold.
Step 2 — Check continuous demand against rated output torque
Compare against rated output torque, not maximum torque. If continuous demand is close to 260 Nm, the PLT-198 is at the edge of its envelope; if it is far below, a lower-ratio, lower-power assembly is likely to be the better match.
Step 3 — Check peak demand against maximum torque
Acceleration and emergency braking are short-duration events. The PLT-120 publishes a separate maximum acceleration and braking torque figure of 20 Nm and 42 Nm for its two ratios, which shows how continuous and peak values are deliberately published side by side in this product family. Use the equivalent peak column for whichever model you shortlist.
Step 4 — Convert required travel speed into a ratio ceiling
Work backwards from the target travel speed and the intended wheel diameter to find the maximum wheel RPM you can accept, then multiply by the ratio to see what motor speed it implies. At 3000 RPM motor speed, a 32:1 unit delivers about 93.75 RPM at the wheel.
Step 5 — Confirm the load and floor interface
Match maximum load to the real axle load, including payload shift during braking. PU tread is common on forklift drive wheels because it protects indoor floors while carrying high loads (Mordor Intelligence). The corpus range covers 150 kg (PLT-120) through 800 kg (PLT-167), 1000 kg (PLT-220), 1200 kg (PLT-210 and PLT-230P) and 1500 kg (PLT-198 and PLT-230).
Step 6 — Confirm the installation envelope and configuration
Ratio and torque rarely decide the layout; orientation usually does. Horizontal configurations keep chassis height low, while vertical configurations suit compact heavy-load designs. The PLT-120 is a differential drive wheel with IP65 protection and a 150 kg wheel load; the PLT-230P is a vertical drive wheel with shock absorption, IP65 rating and a 1200 kg load; the PLT-167 is a horizontal unit without steering at 21:1.
Step 7 — Verify compliance evidence
Ask for the certificate number, the laboratory, the covered model scope and the expiry date. Plutools holds CE certification AT1814C500806124, issued by Shenzhen Anbotek Compliance Laboratory Limited, covering the PLT series (50 W–20,000 W) and assessed against EN ISO 12100:2010 and EN 60204-1:2018, valid from 2 April 2025 to 2 April 2030.
Step 8 — Validate on your own vehicle
Ratio behaviour depends on your duty cycle, control loop and floor. A bench spec sheet cannot replace a pilot build, which is why the sampling step exists (see FAQ below).
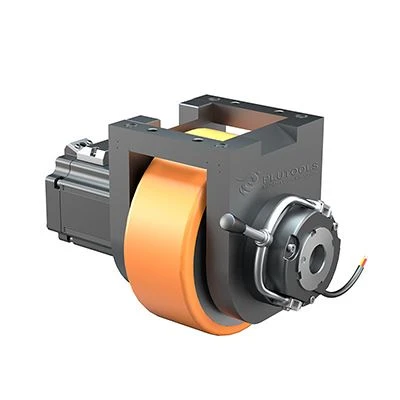
Figure 3 — Lower-ratio alternatives such as the 21:1 PLT-167 suit lighter platforms where 260 Nm of wheel torque is more than the duty requires.
When 32:1 Fits — and When It Does Not
| Choose 32:1 when | Move to a lower ratio when |
|---|---|
| Continuous wheel torque demand approaches the 200–260 Nm band | Continuous demand sits comfortably under roughly 100 Nm |
| Payload and axle loads are heavy — up to the 1500 kg rating of the PLT-198 | Payload is light and a smaller wheel load rating is sufficient |
| Ramps, frequent starts, braking on slopes or tug duty dominate the duty cycle | Long, flat, high-speed transport legs dominate |
| Top travel speed is moderate and low-speed positioning accuracy matters more | High top speed with a large wheel diameter is the primary requirement |
| The chassis can take a 3000 W, 48 V, 68 A drive unit and the battery sizing that follows | Available power, current budget or chassis space is limited |
Use Cases: Where 32:1 Has Been Specified
A representative project is an ultra-heavy-duty AGV programme for an AGV manufacturer and industrial automation system integrator in Brazil. The application required drive, differential steering and precise motion control across multiple navigation modes; 200 units were supplied over a two-year programme. Reported outcomes were stable operation under heavy-load conditions, accurate route tracking, flexible steering and reliable material transportation, with the key requirements listed as high load capacity, high output torque, precise differential control, multiple navigation compatibility and stable system integration.
Beyond that, 32:1-class units are typically specified for automated forklifts and lifting platforms, heavy pallet transport, production-line transfer, and airport or port transfer vehicles. Lower ratios serve different niches: the PLT-167 at 21:1 for lighter horizontal platforms, the PLT-220 at 28:1 for mid-range parallel horizontal steering units, and the PLT-120 differential drive wheel with its 9:1 and 20:1 transmission options for small, agile bots that rely on zero-turn-radius behaviour.
Environment also shapes the decision. Drive wheels in this class operate in indoor factories, automated warehouses, production workshops, logistics centres and semi-outdoor industrial environments, with continuous operation, frequent starts and stops, narrow aisles, dust, vibration and temperature variation. Depending on the project, versions can be engineered for low-temperature warehouses, high-humidity areas, cleanrooms, dusty workshops and heavy-duty industrial use.
Comparison Table: Reduction Ratio and Published Ratings Across the Plutools Range
| Model | Configuration | Ratio | Motor | Rated motor torque | Rated output torque | Max torque | Max load |
|---|---|---|---|---|---|---|---|
| PLT-120 | Differential drive wheel | 9:1 / 20:1 | 400 W, 48 V | 1.28 Nm | 10 Nm / 21 Nm | 20 Nm / 42 Nm (max acceleration and braking) | 150 kg |
| PLT-167 | Horizontal, without steering | 21 | 750 W, 48 V | 2.4 Nm | 40 Nm | 120 Nm | 800 kg |
| PLT-150 | Vertical, with steering | 22.5 | 750 W, 48 V | 2.4 Nm | 108 Nm | 114 Nm | 500 kg |
| PLT-220 | Parallel horizontal, with steering | 28 | 750 W, 48 V | 2.4 Nm | 58 Nm | 174 Nm | 1000 kg |
| PLT-230 | Vertical, without steering | 30 | 1500 W, 24 V | 5.5 Nm | 108 Nm | 300 Nm | 1500 kg |
| PLT-230P | Vertical, with shock absorption | 30 | 2500 W servo, 48 V, IP65 | — | — | — | 1200 kg |
| PLT-198 | Planetary horizontal, with steering | 32 | 3000 W, 48 V | 9.55 Nm | 260 Nm | 576 Nm | 1500 kg |
| PLT-210 | Parallel horizontal, with steering | 32 | 3000 W, 48 V | 9.55 Nm | 260 Nm | 576 Nm | 1200 kg |
Two observations follow from the table. First, moving from 21:1 to 32:1 in this family raises rated output torque from 40 Nm to 260 Nm while the load rating climbs from 800 kg to 1500 kg — ratio and load are correlated here but are still published as separate ratings. Second, the PLT-198 and PLT-210 share an identical ratio and identical torque figures, yet differ in maximum load and structural configuration, so the final choice is made on mounting, steering and chassis integration, not on ratio alone.
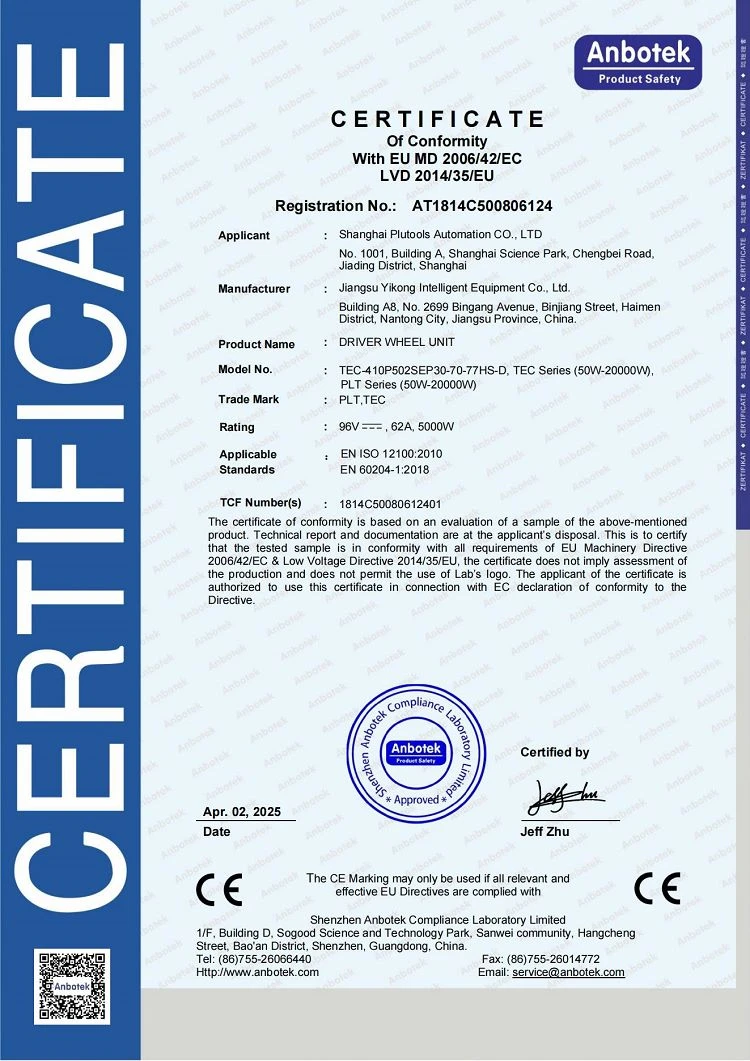
Figure 4 — CE certification covering the PLT series, issued by Shenzhen Anbotek Compliance Laboratory Limited.
FAQ: 32:1 Drive Wheel Constraints Buyers Ask About
Which standards and certifications should a 32:1 AGV drive wheel meet?
For Europe, AGV drive wheel assemblies are normally assessed against EN ISO 12100:2010 for risk assessment principles and EN 60204-1:2018 for the electrical equipment of machines, alongside ISO 3691-4:2023, the international safety standard for driverless industrial trucks, which covers steering and braking systems. EN 1175:2020 specifies the electrical and electronic safety requirements for industrial trucks and applies to drive wheel assemblies; in the United States the corresponding reference is ANSI/ITSDF B56.5. Plutools holds CE certification number AT1814C500806124, issued by Shenzhen Anbotek Compliance Laboratory Limited for the TEC series (50 W–20,000 W) and the PLT series (50 W–20,000 W), assessed against EN ISO 12100:2010 and EN 60204-1:2018, valid from 2 April 2025 to 2 April 2030; an earlier certificate, AT182414C4001881, covers the same PLT power range. Always confirm the certificate number, the issuing laboratory, the model scope and the expiry date, because a certificate that does not name your model is not evidence.
Can the 32:1 ratio be changed, and what else can be customized?
Yes. Reduction ratio is one of the customizable parameters, together with load capacity, wheel diameter, motor power, voltage, rated speed, mounting dimensions, encoder type, brake system, connector, cable length, logo and packaging. Plutools operates as a factory offering OEM, ODM and custom manufacturing, from sample development through to production runs in small to large batches, with a monthly capacity of 12,000 units, a minimum order quantity of 2 units and 100% testing.
What should go into a budget comparison for a 32:1 drive wheel?
A reduction ratio on its own carries no price information, so a credible budget comparison has to be built on the whole drive assembly and the load it removes from the rest of the vehicle. Compare integrated assemblies against discrete motor, gearbox, wheel, encoder and brake combinations, because an integrated unit reduces part count, installation space and assembly labour. Then normalize the quotes: same torque, same speed, same load rating, same IP protection, same encoder and brake specification, same connector and cable length, and the same certification evidence. Units that differ on any of these are not comparable line items.
How should a 32:1 drive wheel be validated before a production run?
Validate it as a system, not as a catalogue number. Sample development is offered, and the minimum order quantity is 2 units, which is enough for a pilot vehicle. Fit the units to your own chassis, run your own duty cycle including the heaviest gradient and the most aggressive braking event, and confirm that continuous torque stays within the rated output figure, that peak events stay within the maximum torque figure, and that the measured travel speed matches what the wheel diameter and output RPM predicted. Because customization covers ratio, wheel diameter, encoder type and brake system, any deviation found at this stage can be corrected in the specification rather than in the field.
What is the lead time and production capacity for a 32:1 drive wheel order?
Standard lead time is 30–45 days, with a monthly production capacity of 12,000 units and a minimum order quantity of 2 units. Customized specifications — ratio, wheel diameter, encoder type, brake system or mounting dimensions — should be confirmed before the lead time is fixed, since the customization scope defines the production route. Export markets served include the EU, the US, the Middle East and Southeast Asia. If you want to move from research to evaluation, the fastest next step is to request a sample or a quote against your torque, speed and load targets so the ratio can be checked on real hardware rather than on a datasheet.
Conclusion
A 32:1 reduction ratio is a deliberate engineering choice for vehicles that need high continuous torque at moderate speed: on the PLT-198 it converts 9.55 Nm of rated motor torque at 3000 RPM into 260 Nm of rated output torque at roughly 93.75 RPM, with a 576 Nm maximum torque and a 1500 kg load rating. The three rules that prevent most specification errors are simple. Size from published output torque, not from the arithmetic product. Size continuous duty from rated torque and short-duration events from maximum torque. And treat ratio and load capacity as separate decisions, because models with identical ratios can still carry different loads.
For AGV and AMR engineers, the ratio question is answered by three inputs: the torque your worst-case duty cycle demands, the top speed your route requires, and the wheel diameter your chassis allows. Once those are fixed, the ratio follows, and the remaining work is compliance evidence, sample validation and lead time.
Next Step: Validate 32:1 on Your Own Vehicle
Send your torque, speed, wheel diameter and load targets, and Plutools will confirm whether the PLT-198 at 32:1 — or a lower-ratio unit such as the PLT-167 at 21:1 or the PLT-220 at 28:1 — matches your duty cycle. Samples start at 2 units.
Request a Sample or QuoteDownload the 2026 Selection Catalogue (PDF)
Email: Eric.Tang@plutools.com · Tel / WhatsApp: +86 159-8958-6580 · Chat on WhatsApp
Shanghai Plutools Automation Corporation Co., Ltd. · No. 1001, Building A, Shanghai Science Park, Chengbei Road, Jiading District, Shanghai, China · www.plutools.com
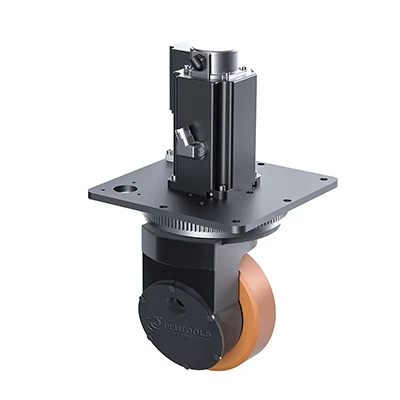
Figure 5 — Ratio, torque and load can be matched to your vehicle before tooling is committed. Request a sample to validate on your own floor.